A robot you can teach rather than program.
An operator does the job through the robot, and Yuri remembers the skill. Every run is a demonstration, and the demonstrations are Yuri’s training data.
Physical AI robot
Yuri is a dual-arm humanoid robot that does real work from day one — an operator does the job through the robot, and Yuri remembers the skill. Physical AI increases how much work is possible. Designed, assembled, shipped and supported in Southlake, Texas.
Yuri is a complete Physical AI robot stack in one supported platform — OpenArm 2+ arms, MobileBase™, OpenLeader force-feedback teleop, a preconfigured NVIDIA AGX Orin, and Sensori’s browser setup app. Built and supported in the USA, with setup guidance included.
An operator does the job through the robot, and Yuri remembers the skill. Every run is a demonstration, and the demonstrations are Yuri’s training data.
Built in Southlake, Texas, with setup guidance and support included in the purchase.
Yuri is teleoperated until the task reaches 100% automation. The first part of that process is what the platform is built for.
Contains simulated and teleoperated footage. Shipped model may differ from video.
Detailed arm DOF, camera, compute, and software specifications live on the Specs page.
Both configurations ship integrated — arms, leaders, compute, calibration, software, and support. Yuri Mobile adds MobileBase™ for room-scale autonomy.
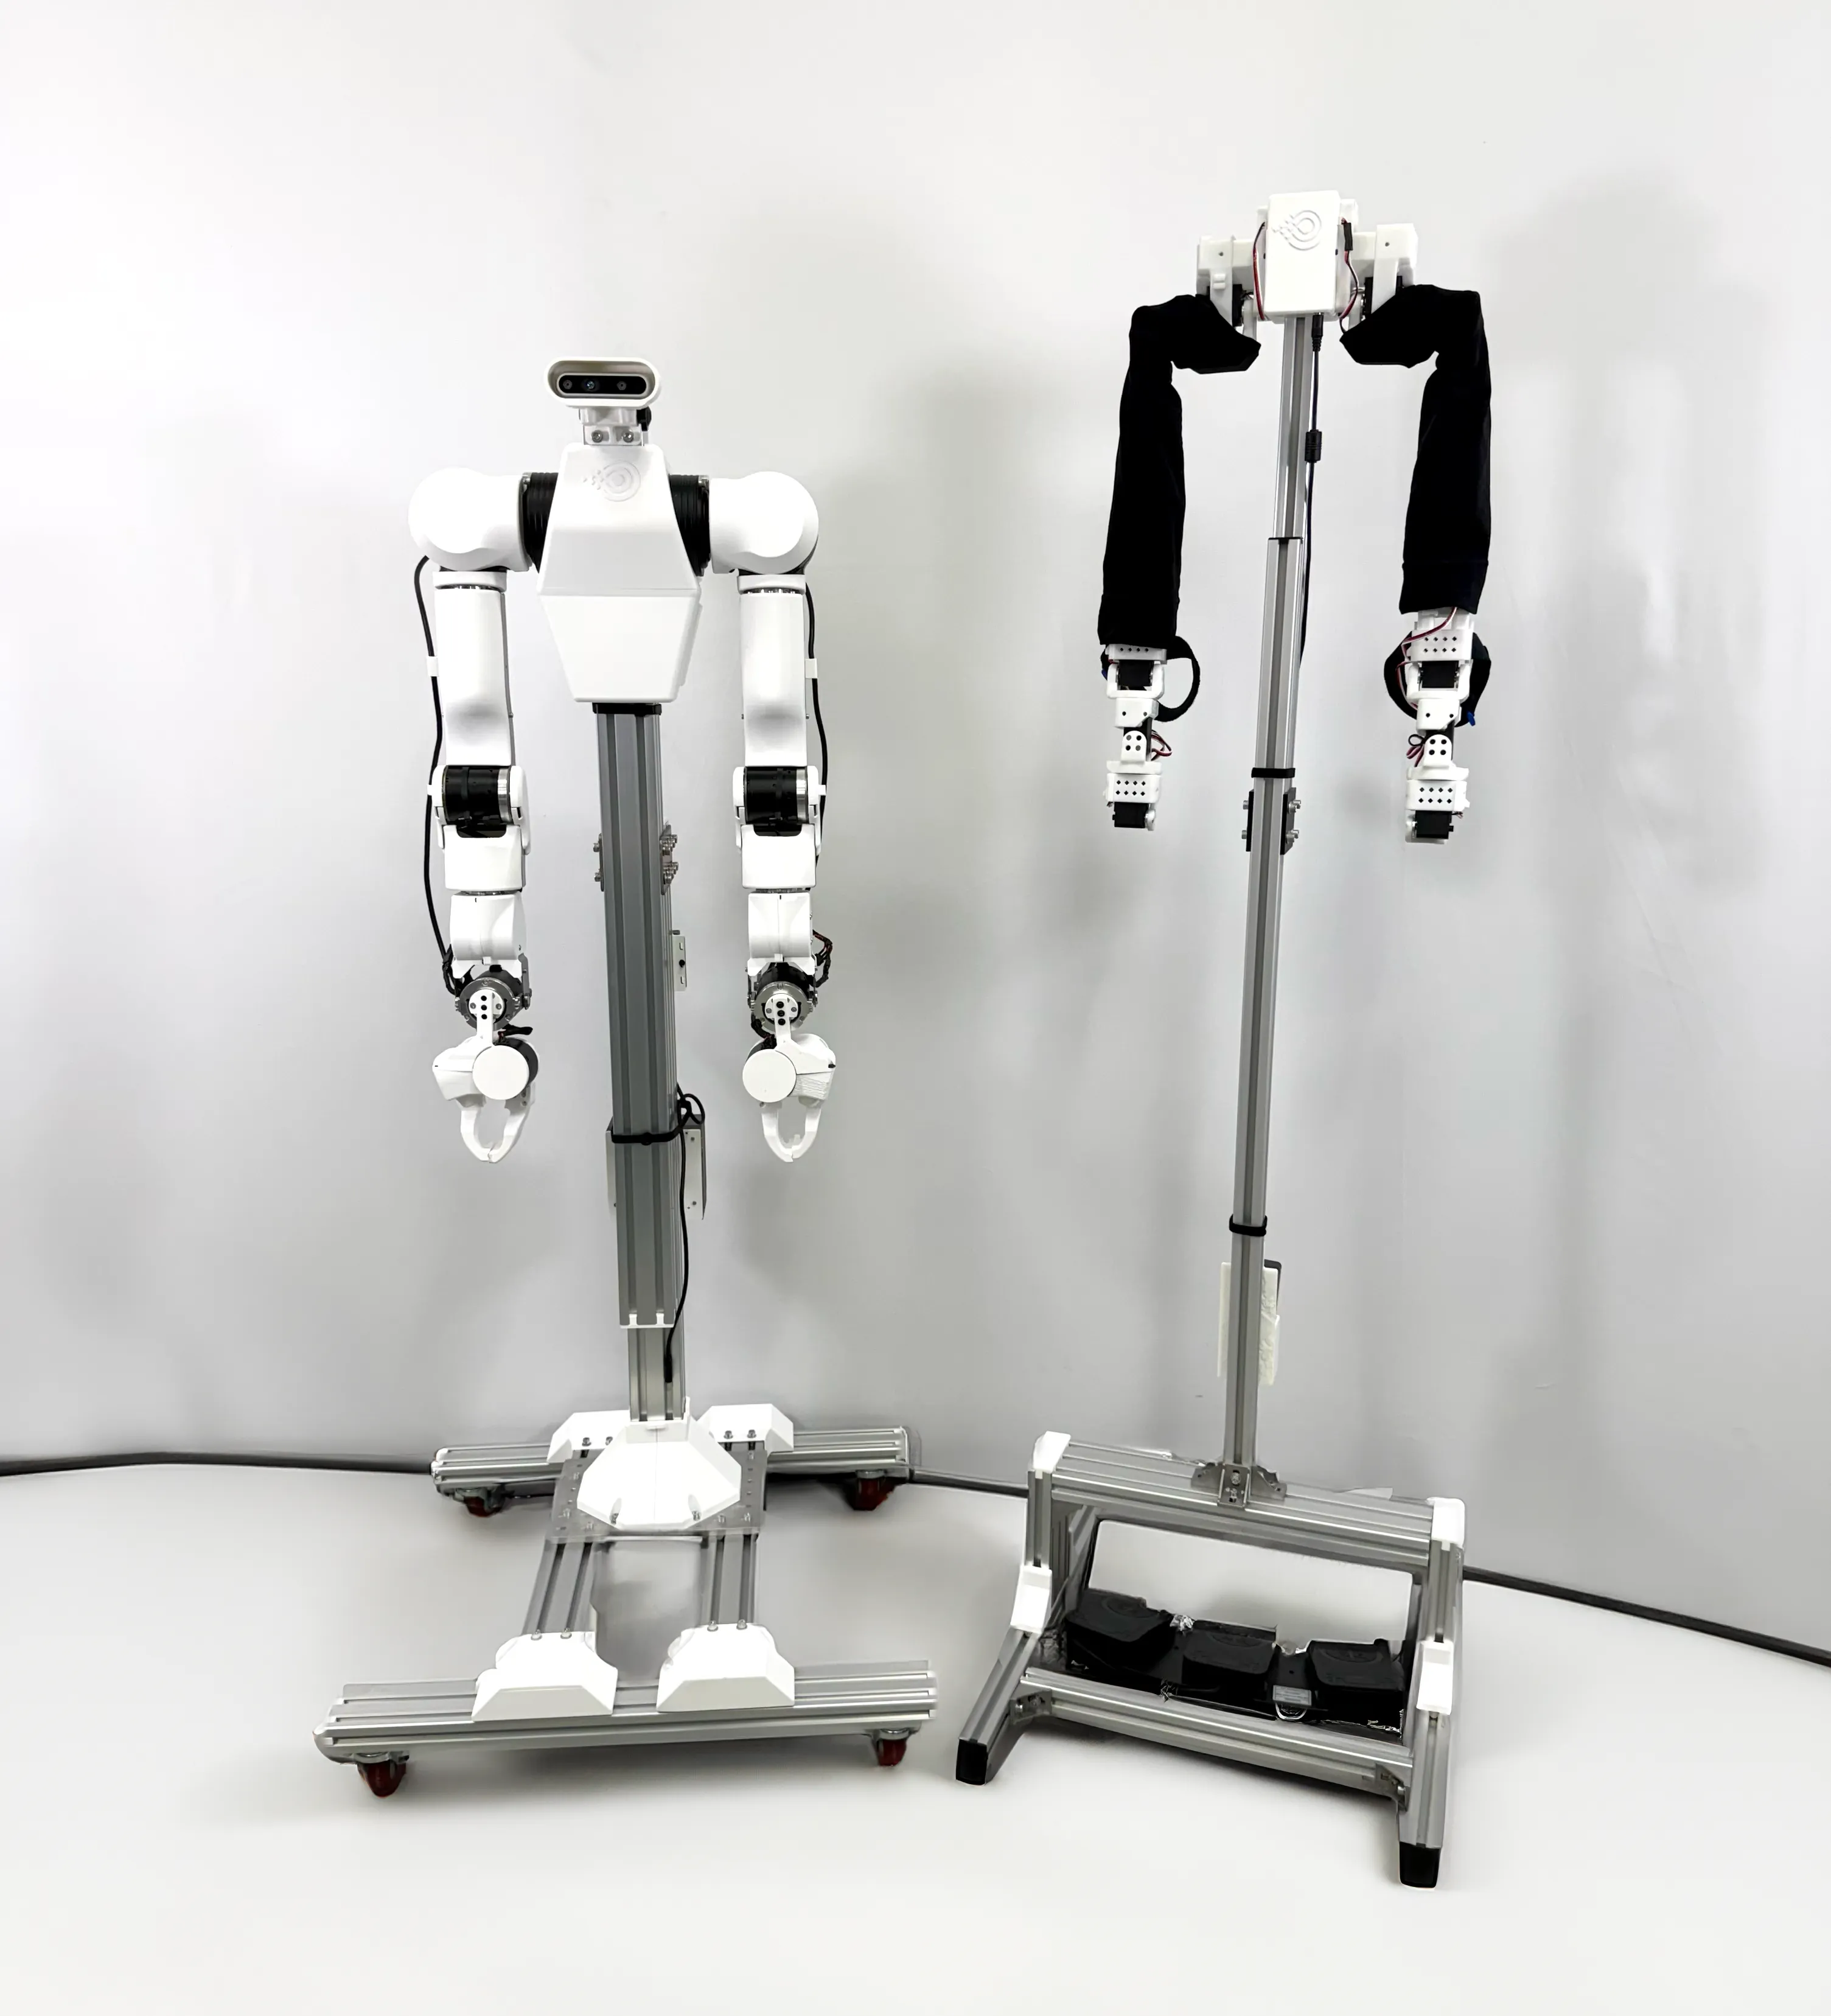
Bench-top bimanual robot.
Bench-top bimanual robot for labs that want manipulation, teleop, dataset collection, and policy evaluation without a mobile base.
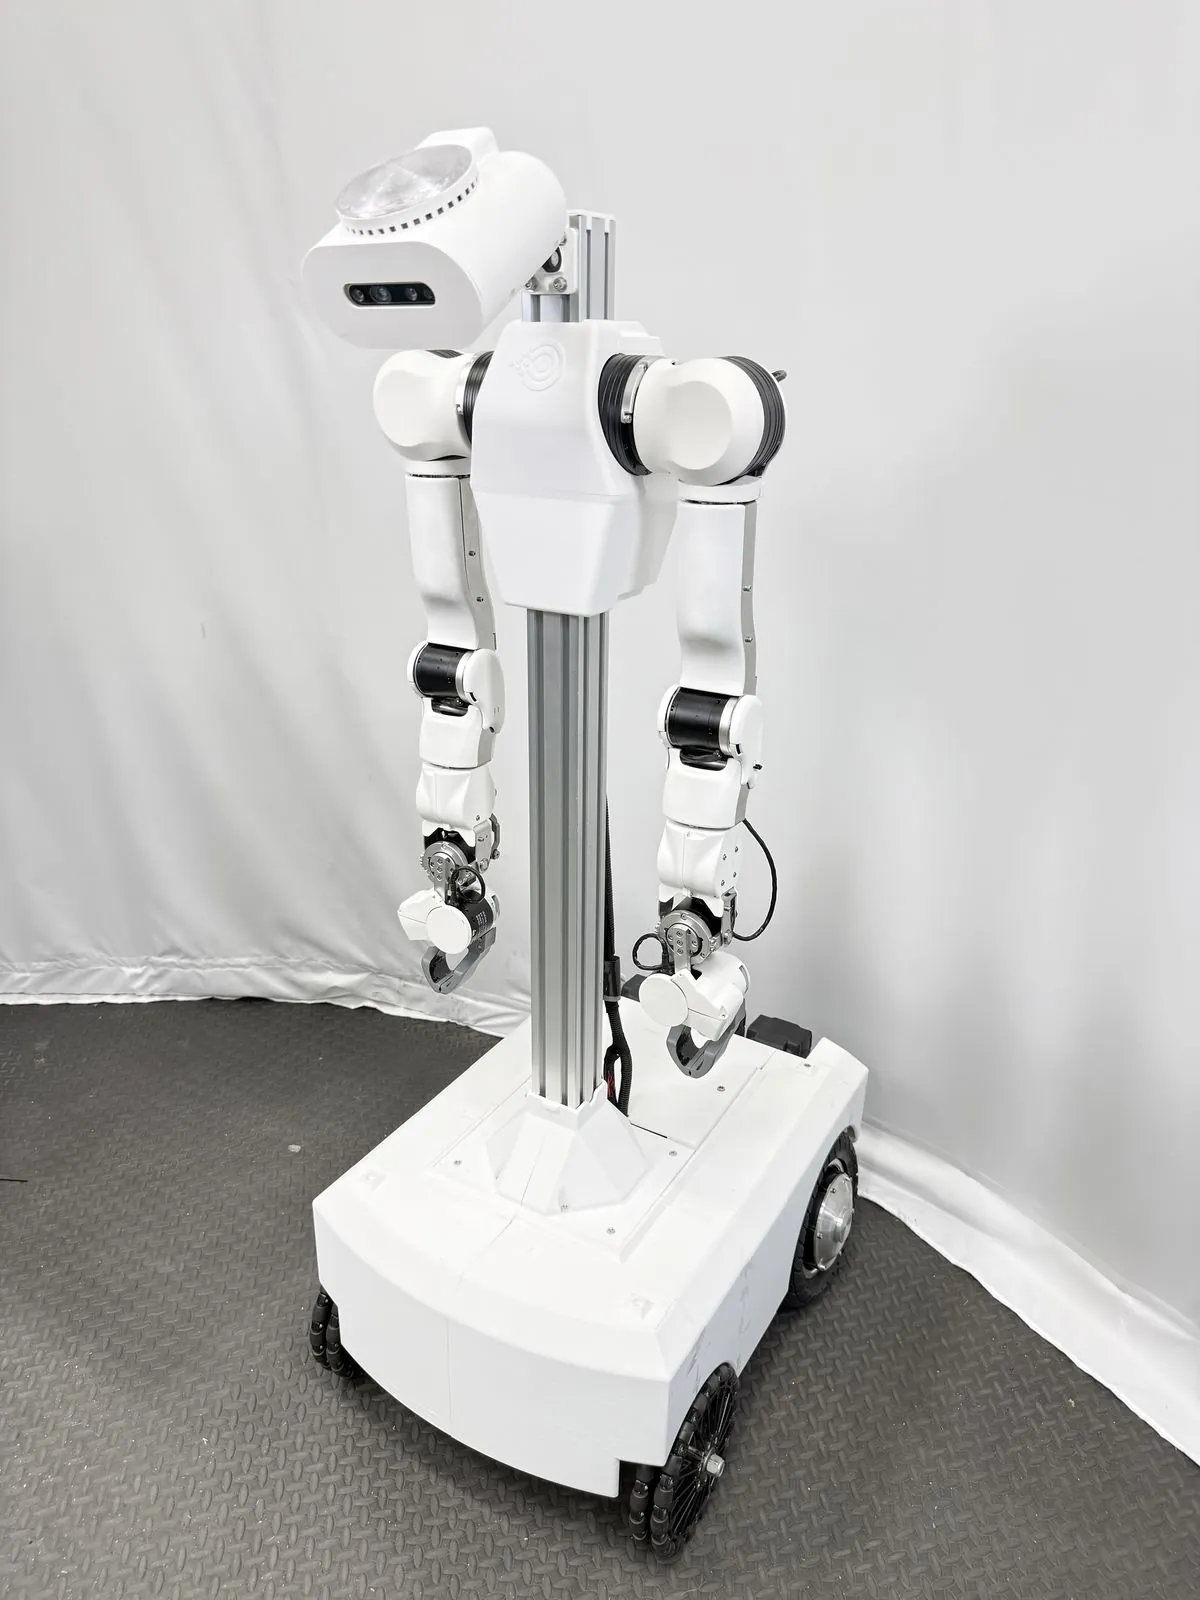
Shipped model may differ from image.
Wheeled humanoid for real-world tasks.
Everything in Desktop, mounted on MobileBase™ for bimanual manipulation across offices, labs, homes, and demo environments.
Yuri is built around the loop Physical AI teams actually need: collect demonstrations, train policies, evaluate rollouts, improve the dataset, repeat.
Quest 3/3S teleoperation support for spatial, whole-body demonstration capture over local Wi‑Fi.
OpenLeader arms support bilateral teleop modes for force-rich manipulation where operator feel matters.
Record synchronized cameras, joints, grippers, base state, and language labels directly into training-ready datasets.
Designed for GR00T, Pi‑0.x, X‑VLA, SmolVLA, and custom policy evaluation on real bimanual tasks.
Every run is a demonstration, and the demonstrations are Yuri’s training data.
Contains simulated and teleoperated footage. Shipped model may differ from video.
This is Yuri, and this is how a robot learns a job.
Shipped model may differ from video.
Shipped model may differ from video.
Yuri is built around the loop Physical AI teams actually need — teleoperate, collect, train, evaluate, repeat. Each capability has its own page explaining how it works and what it produces.
OpenLeader force-feedback leader arms, Quest 3/3S VR teleop, bilateral and unilateral modes, fallback joystick/web control.
Read Teleoperation → 02Operator intent, joint state, gripper state, camera frames, and language labels — synchronized and exported as LeRobot datasets.
Read Robot Data Collection → 03Cloud training, on-robot inference, rollout evaluation, and deployment back onto Yuri. The full loop, one screen.
Read Robot Learning →OpenArm 2+ is Sensori’s extended follower-arm build on the open OpenArm ecosystem, giving Yuri more usable workspace around bins, tabletops, and mobile tasks.
Shipped model may differ from video.
Shipped model may differ from video.
Two 8-DOF OpenArm 2+ follower arms with extended human-scale reach, wrist RGB cameras, and a head-mounted RealSense depth camera for contact-rich bimanual work.
2× wrist-mounted Arducam RGB cameras capture close-up manipulation from the point of contact.
Shipped model may differ from video.
A head-mounted RealSense depth camera — D435 on Yuri Desktop, D435i with IMU on Yuri Mobile — supports contact-rich tasks and can detect people who are too close to the robot.
Backdrivable, torque-aware joints and extended human-scale reach support sorting, pick-and-place, handoffs, and contact-rich tasks across bins, tabletops, and mobile tasks.
Quest teleop of Yuri Desktop. Shipped model may differ from video.
OpenArm 2+ is Sensori’s extended follower-arm build on the open OpenArm ecosystem, giving Yuri more usable workspace around bins, tabletops, and mobile tasks.
8 DOF per arm (7 joints plus gripper), CAN control, DAMIAO actuators, and extended Yuri geometry. The 2+ naming marks Sensori’s build: extended reach plus 2.0 grippers. Details at docs.openarm.dev.
Longer than standard OpenArm for more usable workspace — fully open source at github.com/SensoriRobotics.
Backdrivable, torque-aware joints with mechanical end stops for practical Physical AI training.
Matched leader arms for precise bimanual demonstration capture, bilateral force cues, and low-friction dataset collection.
Contact us about OpenLeaderOpenLeader mirrors the operator’s bimanual intent with smooth, repeatable inputs for teleop and training demos.
Shipped model may differ from video.
Operator motion drives Yuri’s arms in real time — collect contact-rich data while the robot performs the matching motion.
Shipped model may differ from video.
Record synchronized operator, robot, camera, and joint-state data for imitation learning and policy evaluation.
Shipped model may differ from video.
Sensori-modified leader arms with bilateral force feedback, built to match Yuri’s follower motion for high-quality demonstrations. OpenLeader is the name for Sensori’s leader-arm pair.
OpenLeader arms support bilateral teleop modes for force-rich manipulation where operator feel matters.
OpenLeader arms with bilateral force feedback included from day one.
Sensori MobileBase™ adds smooth indoor driving, tight turns, and swappable batteries for room-scale manipulation.
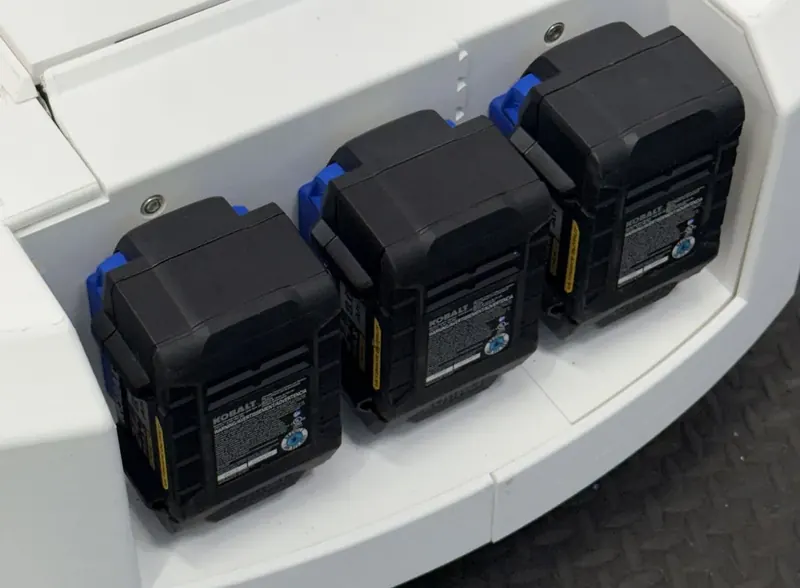
Room-scale training with directional turns for real-world mobile tasks.
Shipped model may differ from video.
Hot-swappable batteries and hardware/wireless e-stop, with the same day-one teleop and recording workflow as Desktop.
Sensori’s wheeled base gives Yuri room-scale mobility, a compute/sensor deck, swappable battery support, and a practical platform for mobile manipulation development.
Move the robot to the task instead of rebuilding the task around a fixed arm — across offices, labs, homes, and demo environments.
A head-mounted RealSense depth camera detects people who are too close to the robot.
Yuri includes the software layer normally left to the buyer: a preconfigured AGX Orin, browser-based setup, drivers, calibration, teleop, recording, visualization, and sim assets.
Telepath
Telepath runs on the robot and opens in any browser — laptop, tablet, phone, or a VR headset. Every status on screen is verified against the hardware in real time.
No terminal, no code, no environment variables in daily use.
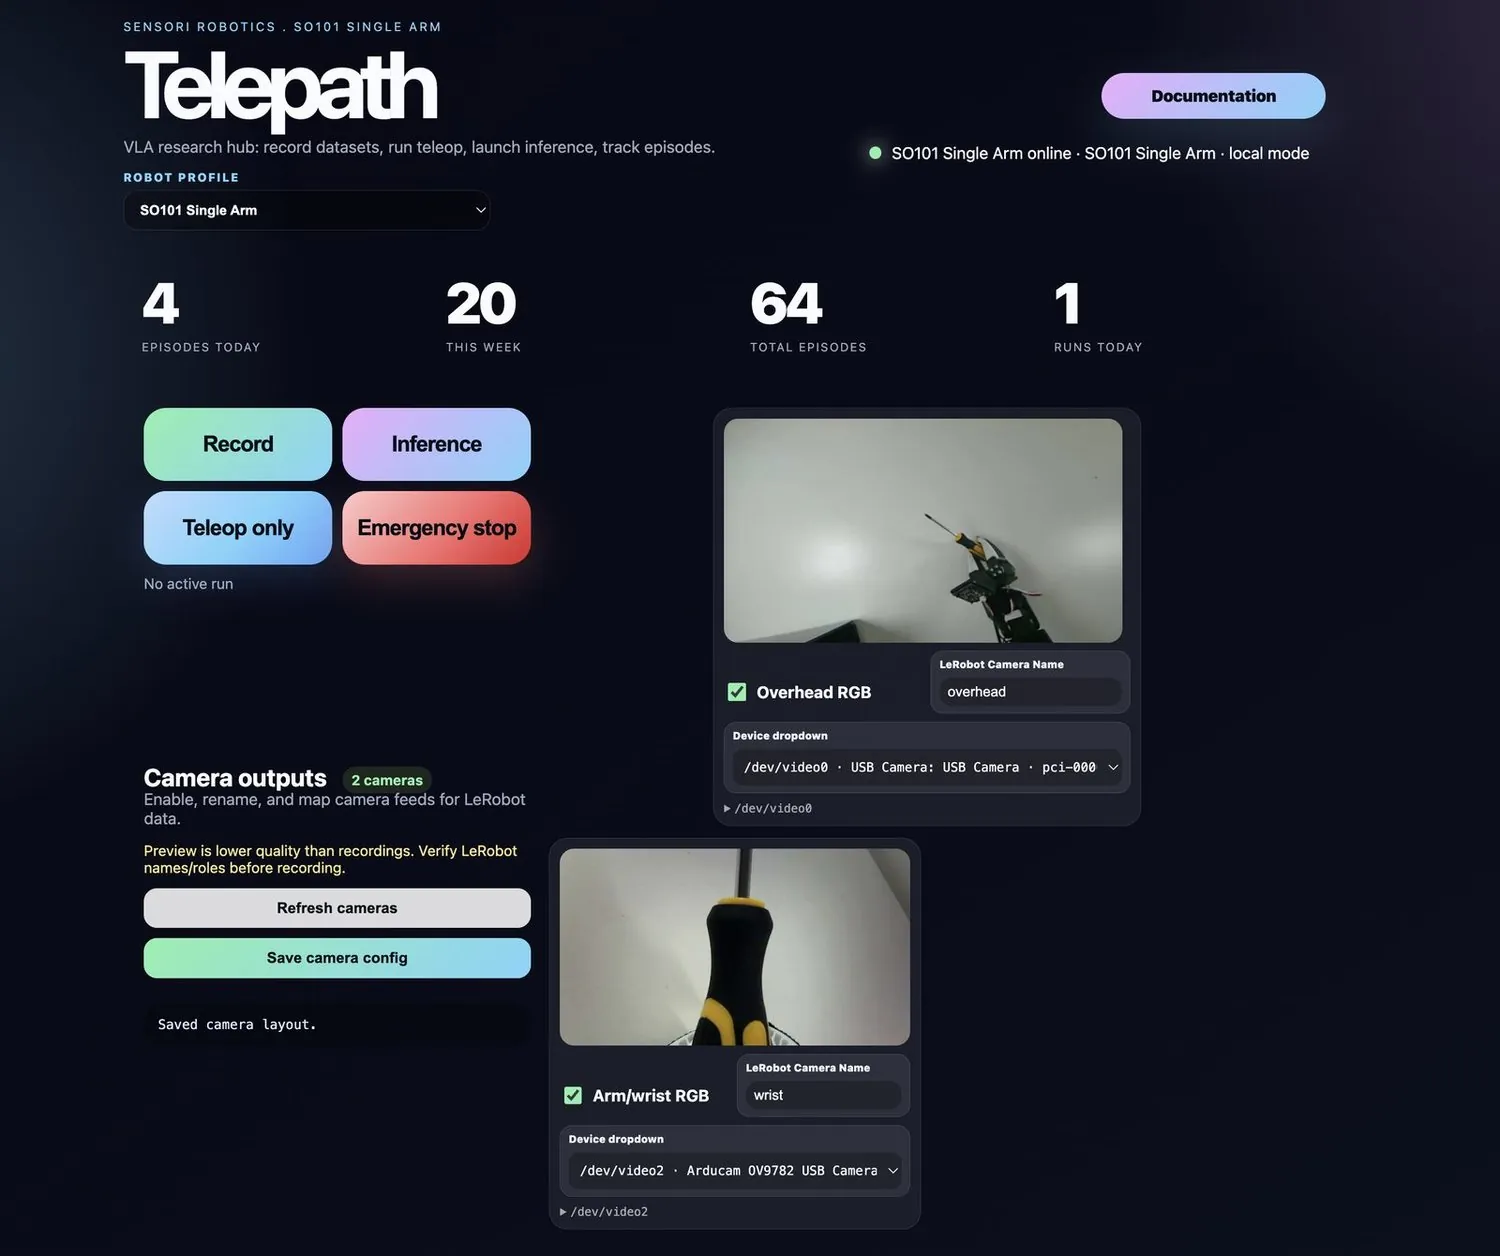
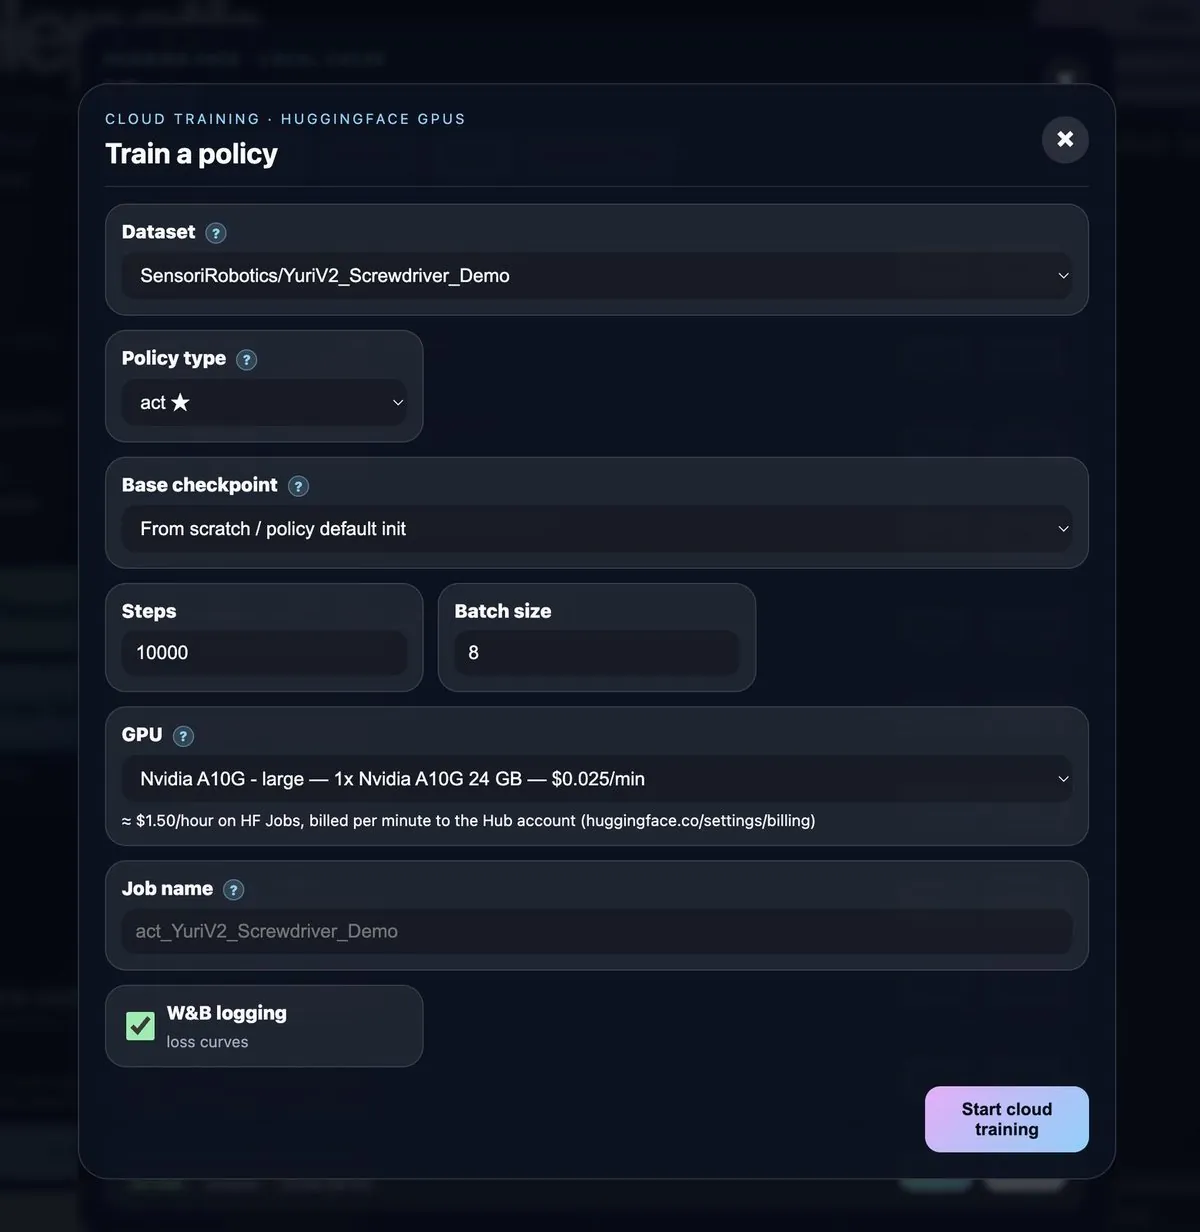
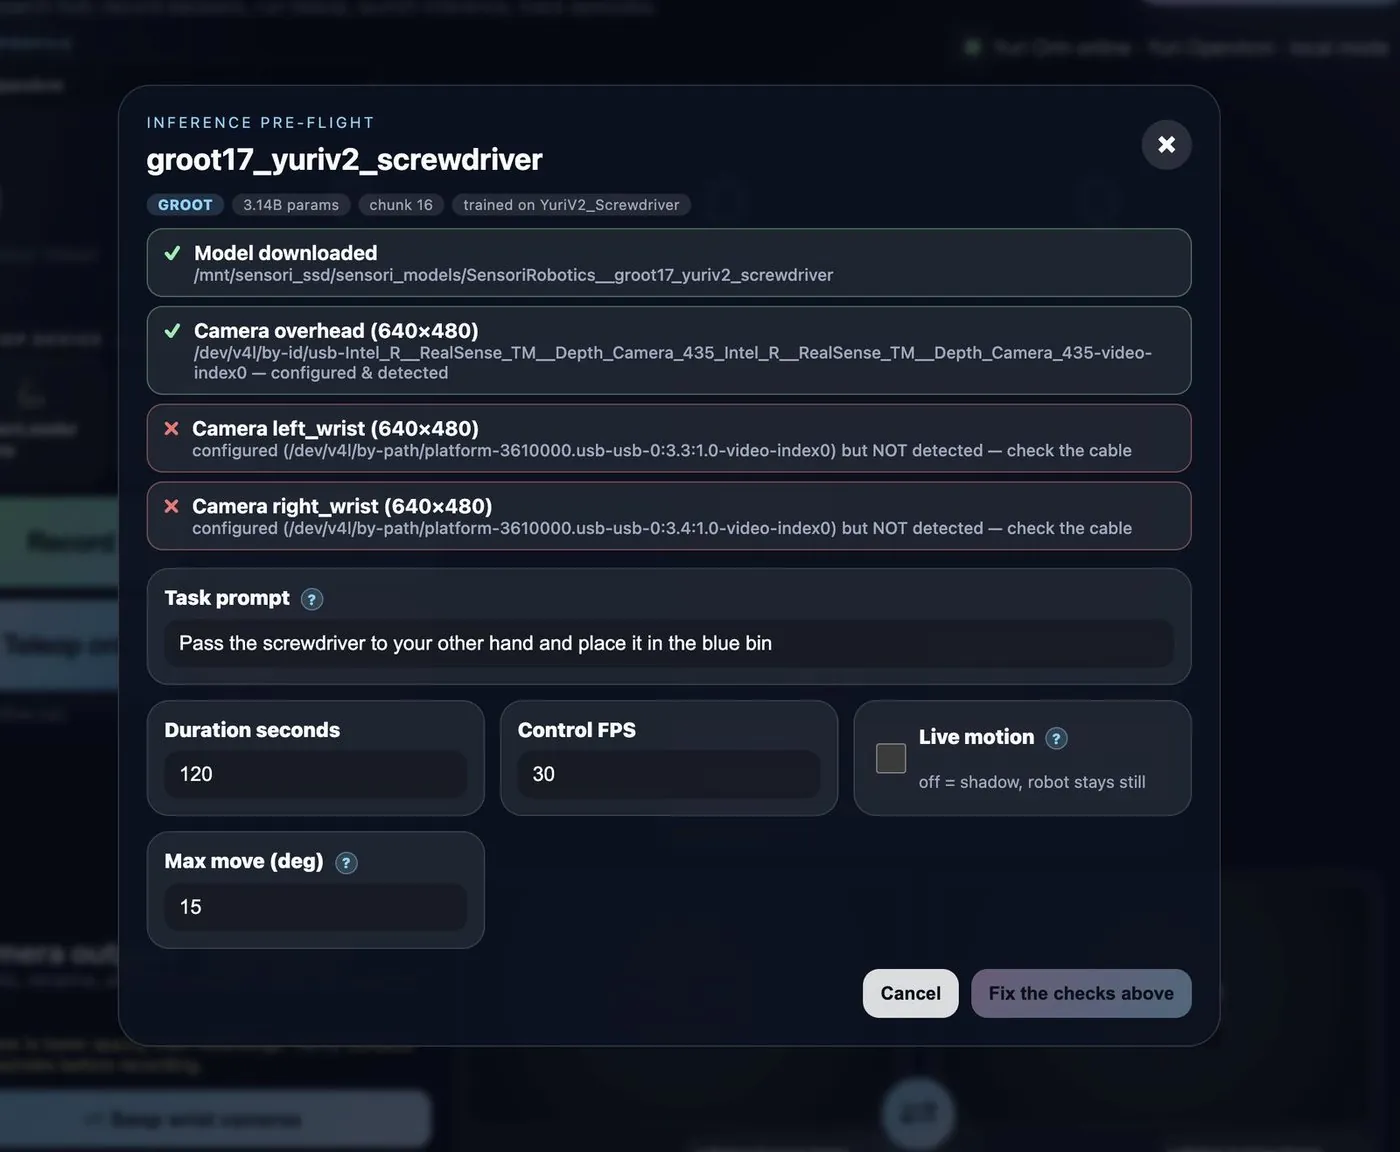
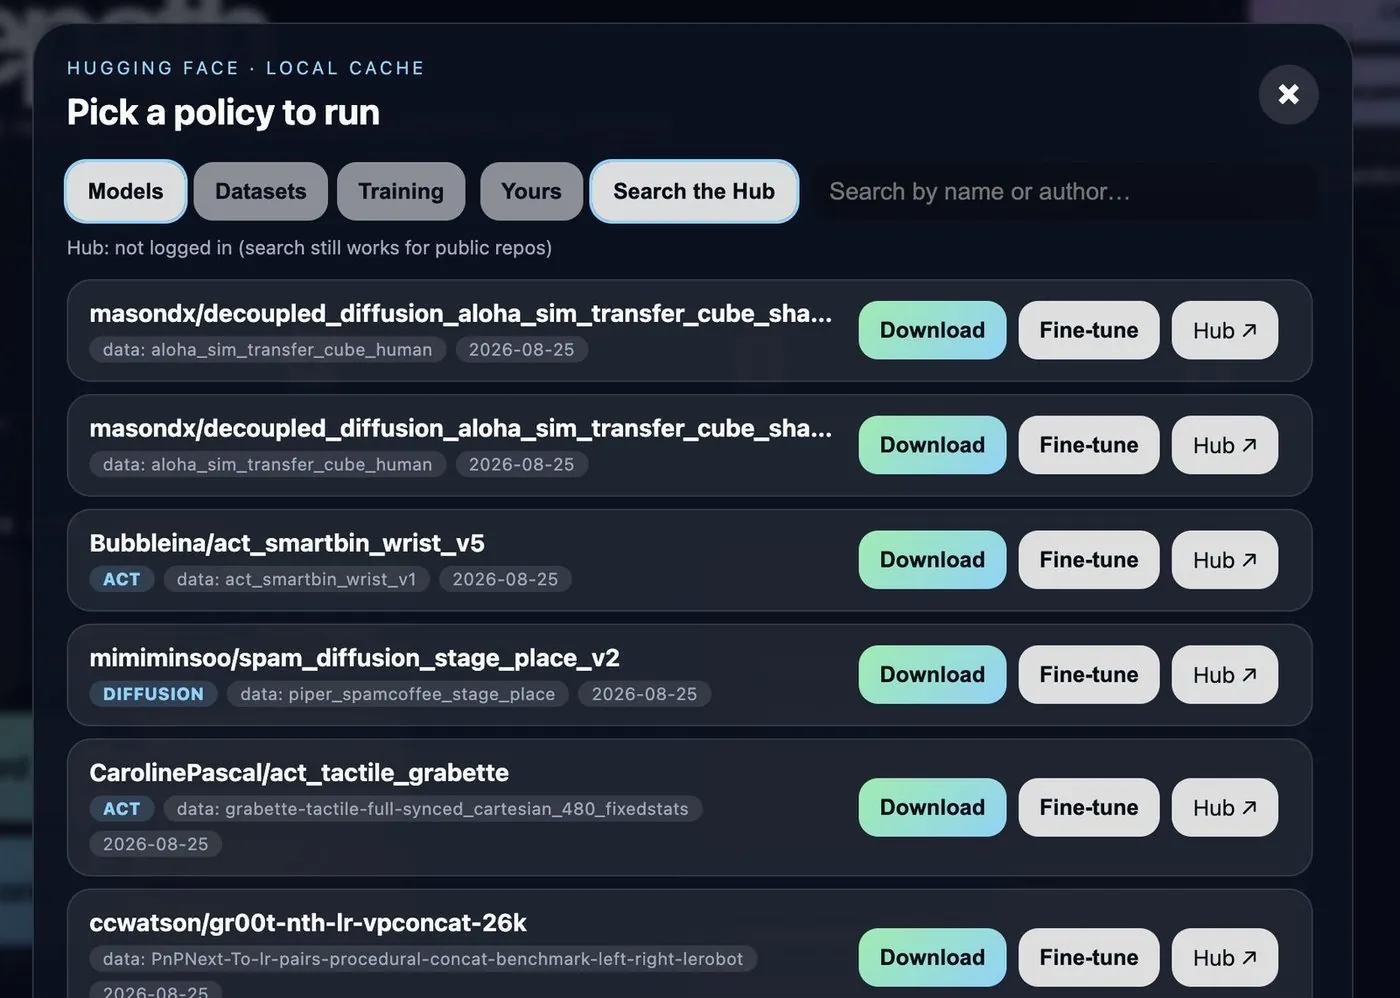
Guided setup finds the arms and cameras and remembers them.
Teleoperate the robot and record episodes.
Pick a model, pick a GPU, one click. Training runs in the cloud.
A safety checklist, then the robot performs the task on its own.
Preconfigured AGX Orin with ROS 2 Humble, Sensori CAN arm driver, base driver, gravity compensation, and launch files.
Quest 3/3S IK teleop, OpenLeader bilateral/unilateral modes, joystick/web fallback, low-latency local operation.
LeRobot dataset export, MCAP logging, Foxglove visualization, camera/joint sync, repeatable recording.
URDF/MJCF assets for MuJoCo, Isaac Lab, and Genesis — for sim-to-real iteration and policy debugging.
A high-level summary. Full technical detail — per-configuration cameras, compute, software versions, and hardware — lives on the Specs page.
| Manipulation | 2× 8-DOF OpenArm 2+ follower arms (7 joints plus gripper); 16 total arm DOF; parallel-jaw grippers included; extended human-scale reach; backdrivable, torque-aware joints |
|---|---|
| Teleoperation | 2× OpenLeader force-feedback leader arms; bilateral/unilateral teleop modes; Quest 3/3S VR teleoperation support; joystick/web fallback |
| Compute | Preconfigured NVIDIA Jetson AGX Orin 64 GB, 275 TOPS |
| Sensing | 3 cameras: 2× wrist-mounted Arducam RGB cameras + head RealSense depth camera (D435 on Yuri Desktop, D435i with IMU on Yuri Mobile) |
| Software | ROS 2 Humble, LeRobot dataset export, MCAP logging, Foxglove visualization, Sensori browser setup app, calibration, drivers, launch files, URDF/MJCF assets |
| Policy workflow | Designed for VLA, Pi-0.x, X-VLA, SmolVLA, GR00T, and custom language-conditioned manipulation policies |
| Configurations | Yuri Desktop bench-top bimanual robot; Yuri Mobile wheeled humanoid with MobileBase™ directional indoor mobility |
| Support | Designed, assembled, shipped and supported from Southlake, Texas; setup guidance and support are part of the Yuri purchase |
Contact
Tell us what you want to build, which configuration you’re interested in (Yuri Desktop or Yuri Mobile), and when you want to evaluate Yuri. We’ll follow up with details, pricing, and availability.